Watch a humanoid robot fold a shirt in a product video and the problem looks solved. Two arms. Ten fingers. A smooth reach, a clean fold, a small pause that almost reads like thought. So how do humanoid robots work?
Most explainers answer with a checklist. Sensors, motors, an AI brain, a battery. That list is accurate and close to useless. It tells you the robot has joints. It never tells you why it has around thirty of them instead of the far larger, redundant set your own body runs on, or why adding one more can cost a company a year of engineering.
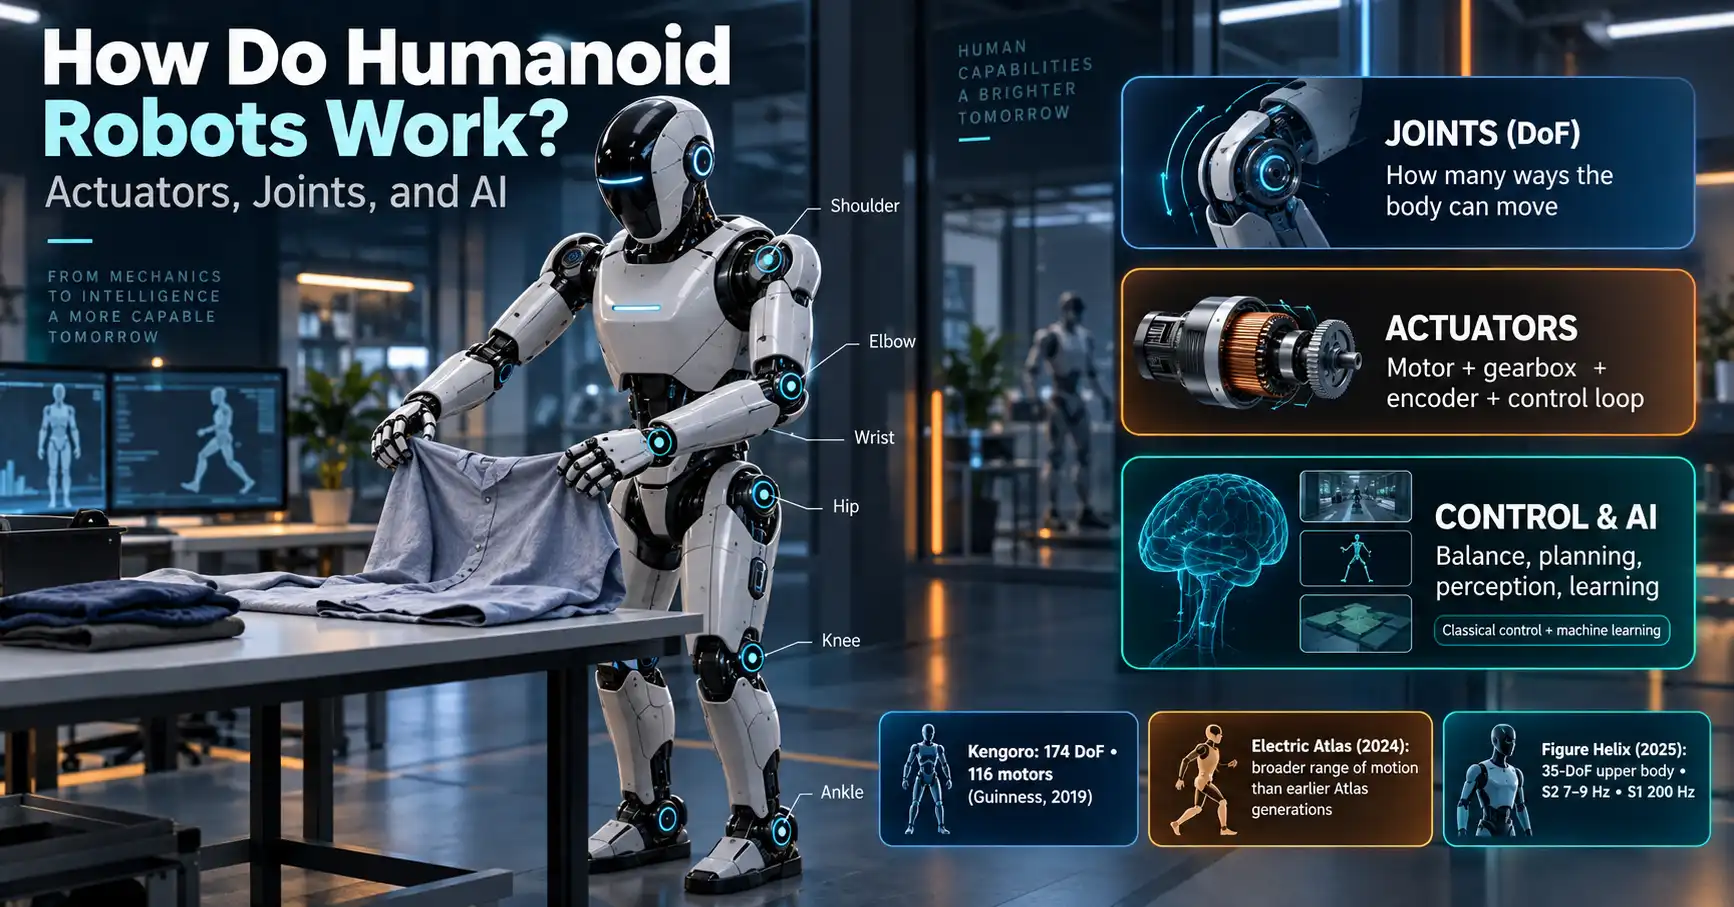
The real answer lives in three layers that compete with each other for budget. A joint count. The actuators that fill it. And a control stack that turns both into balance, continuously, without the machine falling over.
Get those three straight and every robot announcement you read this year becomes much easier to grade.
How do humanoid robots work? Three layers, not one brain
A humanoid robot is not one machine. It’s three systems stacked on each other, and each one limits the next.
At the bottom sits the joint budget: how many independent ways the body can move at all. Above that sit the actuators, the physical devices that drive each of those joints. On top sits the control stack, the software deciding moment to moment what every joint should do.
Marketing talks almost exclusively about that third layer. The AI brain. But the brain can only command motion the body can produce, and the body can only produce what the actuators physically deliver.
So start at the bottom.
The body budget: why around 30 degrees of freedom, not hundreds
Start with the term everyone uses and nobody defines. A degree of freedom is one independent axis of motion that a joint permits: a rotation about one axis, or a slide along one. Your elbow contributes roughly one. Your shoulder contributes three. Count every independent axis in a machine and you have its total DoF.
A typical humanoid robot totals around 30. Roughly six per arm, five or six per leg, and a handful more in the torso and neck. That’s a deliberately lean budget next to the human body, which carries far more axes than any single motion needs.
Why so lean? Because a degree of freedom isn’t a line in a spec sheet. It’s hardware.
Every joint you add, you add six times
Each extra DoF brings a motor. A gearbox. An encoder to report position. A wiring run and a connector. A thermal problem, since motors under load get hot. And one more dimension the control software has to solve in real time, alongside all the others.
The upper bound shows the price clearly. Kengoro, built at the University of Tokyo’s Department of Mechano-Informatics in 2016, holds the Guinness record for the most degrees of freedom in a humanoid robot. The count is 174, including 30 in each hand. Driving them takes 116 individual motors and a human-like spine built from machined-spring joints. Guinness recognized the record in January 2019.
174 axes. 116 motors. One research platform.
No commercial humanoid pays that bill, and that’s exactly the point.
For a sense of what a single joint costs at the small end, look at Tesla’s hands. The company showed an Optimus Gen 2 hand in 2023 with 11 degrees of freedom. The Gen 3 hand in 2024 had 22. Doubling the DoF in one end-effector counted as a headline engineering milestone, and it forced a redesigned actuation and tendon-routing scheme to get there.
One hand. Eleven extra axes. A generational redesign.
Inside an actuator: motor, gearbox, encoder, control loop
An actuator is the thing that moves a joint, and it’s really four parts doing one job.
- The motor produces torque, usually from electric current through windings.
- The gearbox trades speed for torque, because a motor that spins fast and weak is no use at a knee.
- The encoder measures where the joint actually sits and reports it back.
- The control loop compares the commanded position against the measured one, adjusts the current, and repeats.
That last part matters more than people expect. Without the encoder feeding position back, the robot is guessing. With it, the joint becomes a closed loop that corrects its own error continuously. Every smooth motion you’ve seen in a robot video is a long chain of those tiny corrections.
“Actuator” also isn’t one part. It’s a family of mechanical choices tuned to each joint’s load profile. Tesla’s Optimus uses planetary roller screw linear actuators rather than ball screws in some joints, specifically for higher shock-load resistance during walking. A hip absorbing impact every step faces a different problem than a wrist.
Electric or hydraulic? Boston Dynamics already answered
For decades the most athletic humanoids ran on hydraulics. Fluid under pressure delivers enormous force from a compact package, which is how the old Atlas did backflips.
Then Boston Dynamics retired the hydraulic Atlas in April 2024 and introduced an all-electric version. Its stated reasoning is the clearest public account of this trade-off anyone has offered. Removing the hoses and pumps is what freed up range of motion. The company calls the electric Atlas “stronger, with a broader range of motion than any of our previous generations”, and says it will “move in ways that exceed human capabilities” rather than copy a human range.
Read that second phrase again. The design goal isn’t imitation. A shoulder that rotates continuously beats a human shoulder at plenty of real tasks, and electric actuation makes it buildable.
Hydraulics haven’t lost on physics. They still deliver higher raw power density in a small space. Electric wins on control precision, on maintenance, and on deleting a whole class of failures: leaks, seals, fluid. For a machine meant to work in a warehouse rather than a lab, that’s the trade that counts.
Turning 30 joints into a step: the control layer nobody credits
Now you have a body with roughly 30 independent axes and an actuator at each one. Something must decide what all of them do, continuously, while gravity works to tip the whole thing over.
That job belongs to classical control, which predates the current AI wave by decades. Ask how do humanoid robots work and this is the layer that actually answers it.
Inverse kinematics solves a geometry question: you know where the hand should end up, so find the joint angles that put it there. Inverse dynamics solves the harder physics question: what torque does each joint need, given the robot’s mass, its momentum and the forces at its feet? Model-predictive control runs a model of the robot forward a short way into the future, picks the action that keeps it balanced, then discards the plan and recomputes.
Walking is mostly that last one. A humanoid doesn’t walk by playing back a stored animation. It repeatedly predicts where it’s about to fall, and puts a foot there.
Here’s where most explainers go wrong. They frame classical control as legacy tech that machine learning replaced. A January 2025 academic survey of humanoid locomotion and manipulation says the opposite outright: model-based control and sim-to-real reinforcement learning “do not conflict; on the contrary, they often complement each other.” Learned policies still lean on the same accurate dynamics models that drive model-based controllers, because those models are what the simulator is built from.
Machine learning didn’t replace classical control. It moved on top of it.
The AI layer: reinforcement learning, VLA models, and what actually changed
Reinforcement learning and the sim-to-real gap
Reinforcement learning for humanoid locomotion happens almost entirely in simulation. A physics engine runs the robot through attempt after attempt, rewarding the ones that stay upright, until a policy emerges.
The problem is that simulation lies. Real motors heat up and lose torque. Real floors have friction the model got wrong. Real cables stretch and bind.
Engineers fight this with domain randomization. During training they vary body dynamics, actuator characteristics and environmental conditions, so the policy learns to cope with a whole family of slightly wrong worlds instead of one perfect one. That same 2025 survey still names sim-to-real transfer a central challenge in deploying RL-trained humanoids to real-world applications. Not a solved step. A live one.
If the training vocabulary feels fuzzy, our breakdown of supervised, unsupervised and reinforcement learning covers how these approaches differ.
Vision-language-action models: the 2025 shift
An RL walking policy is narrow by design. It walks. It has no idea what a shirt is.
Vision-language-action models closed part of that gap. A VLA takes camera images plus a language instruction and outputs robot actions directly, with no hand-written task script in between.
Figure AI’s Helix, announced on 20 February 2025, is the concrete example. It was the first VLA to control a full 35-DoF humanoid upper body at high rate: wrists, torso, head, individual fingers.
Its architecture exposes a constraint the whole field runs into. Helix splits in two. “System 2” is a 7-billion-parameter internet-pretrained vision-language model handling scene and language understanding, running at 7–9 Hz. “System 1” is an 80-million-parameter visuomotor transformer that outputs continuous control at 200 Hz.
Figure’s own framing of why: “VLM backbones are general, but not fast, and robot visuomotor policies are fast but not general.”
That sentence is the honest summary of robot AI right now. Generality and speed still trade against each other, so you build two brains and wire them together. The slow one thinks. The fast one keeps the robot from dropping the plate.
The big model at the top belongs to the same family as chat assistants, which makes how large language models actually work genuinely load-bearing background for this topic.
Behavior foundation models, and the claim to check
Above VLAs sits the newest idea: behavior foundation models. Train on broad behavior data, get whole-body control that adapts to new tasks with little or no retraining. One model, many skills, any humanoid.
That’s the pitch. The field’s own literature is blunter. The most current survey of behavior foundation models, published in July 2025, states that BFMs “remain largely confined to simulation, with no documented large-scale real-world deployments”.
Read the next vendor demo against that sentence.
Where the real disagreement sits
The fault line in humanoid robotics isn’t classical control versus AI. The 2025 control survey already treats those as partners. The live argument is generalist foundation models versus task-specific learned policies, and the sticking point is data.
Behavior datasets are, per that same July 2025 survey, significantly smaller than the datasets behind large language and vision models. Worse, no existing dataset provides large-scale, temporally aligned recordings of proprioception, vision and contact dynamics together. The physical world offers no equivalent of scraped internet text. Every hour of usable robot data costs somebody an hour of a real robot.
The second problem gets discussed far less. Current behavior foundation models belong to the body they trained on. The survey states plainly that generalizing them to novel embodiments with different body shapes, actuator types or degrees of freedom is currently intractable.
So the popular image of one general robot brain dropping into any humanoid chassis isn’t close. A policy trained on a 35-DoF upper body won’t transfer to a 22-DoF one for free. Change the actuators and you may have changed the problem.
This is also why coverage keeps conflating the hardware race with the software race. They’re separate bets on separate timelines. Our comparison of Tesla Optimus, Figure 03 and Unitree G1 looks at who’s actually shipping bodies. The control question above decides what those bodies can be told to do.
So how do humanoid robots work? Four things to watch
Next time a humanoid demo circulates, skip the fold and the dance. Ask four questions instead.
- How many degrees of freedom, and where? A high hand count signals real manipulation intent. Leg count tells you about mobility, not dexterity.
- Electric or hydraulic, and why that choice? It reveals whether the machine targets a lab or a workplace.
- Where did the policy train, and what happened on real hardware? The sim-to-real gap is where most claims quietly die.
- Is the model general across tasks, or general across bodies? Nobody has the second one yet.
None of this makes humanoid robots less interesting. It makes them legible. A machine with 30 joints, a motor and encoder behind each, a classical controller holding balance, and a two-speed neural stack deciding intent is a remarkable object on its own terms. It simply isn’t a person-shaped mind. Pretending otherwise produces bad regulation and worse expectations about the people these machines will work beside, which is the tension we picked apart in humanoid robot safety.
What would change our reading? One thing. A behavior foundation model that leaves simulation, runs on two different robot bodies, and does a task nobody trained it for. Until somebody publishes that, the joint budget is still the story.