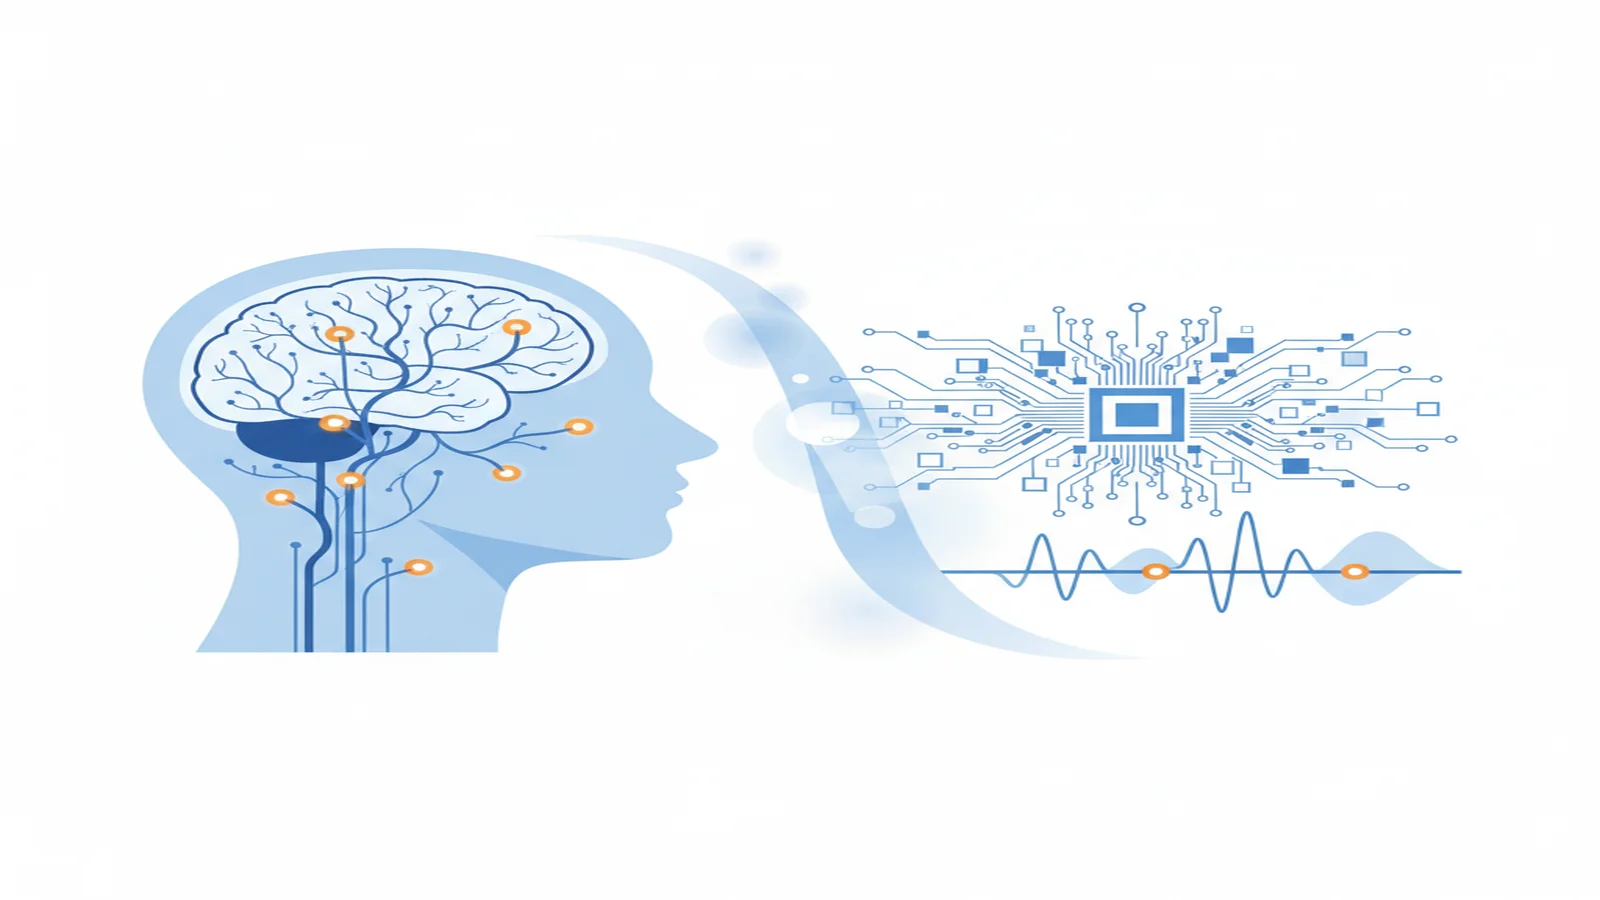
“Mind reading” makes for a great headline and a misleading mental image. A brain-computer interface doesn’t pluck sentences out of your head. It listens to the electrical chatter of neurons, finds patterns it has learned to recognize, and maps those patterns onto a command. It’s closer to lip-reading than telepathy. And that distinction explains both what BCIs can do today and what they still can’t.
Step one: catch the signal
Every thought and movement involves neurons firing, and firing neurons produce tiny electrical changes. BCIs differ mostly in how close they get to that activity:
- Non-invasive (EEG caps): electrodes on the scalp. Easy and safe, but they read a blurry average through skull and skin.
- Partially invasive: electrodes under the skull but on the brain’s surface, trading some risk for a sharper signal.
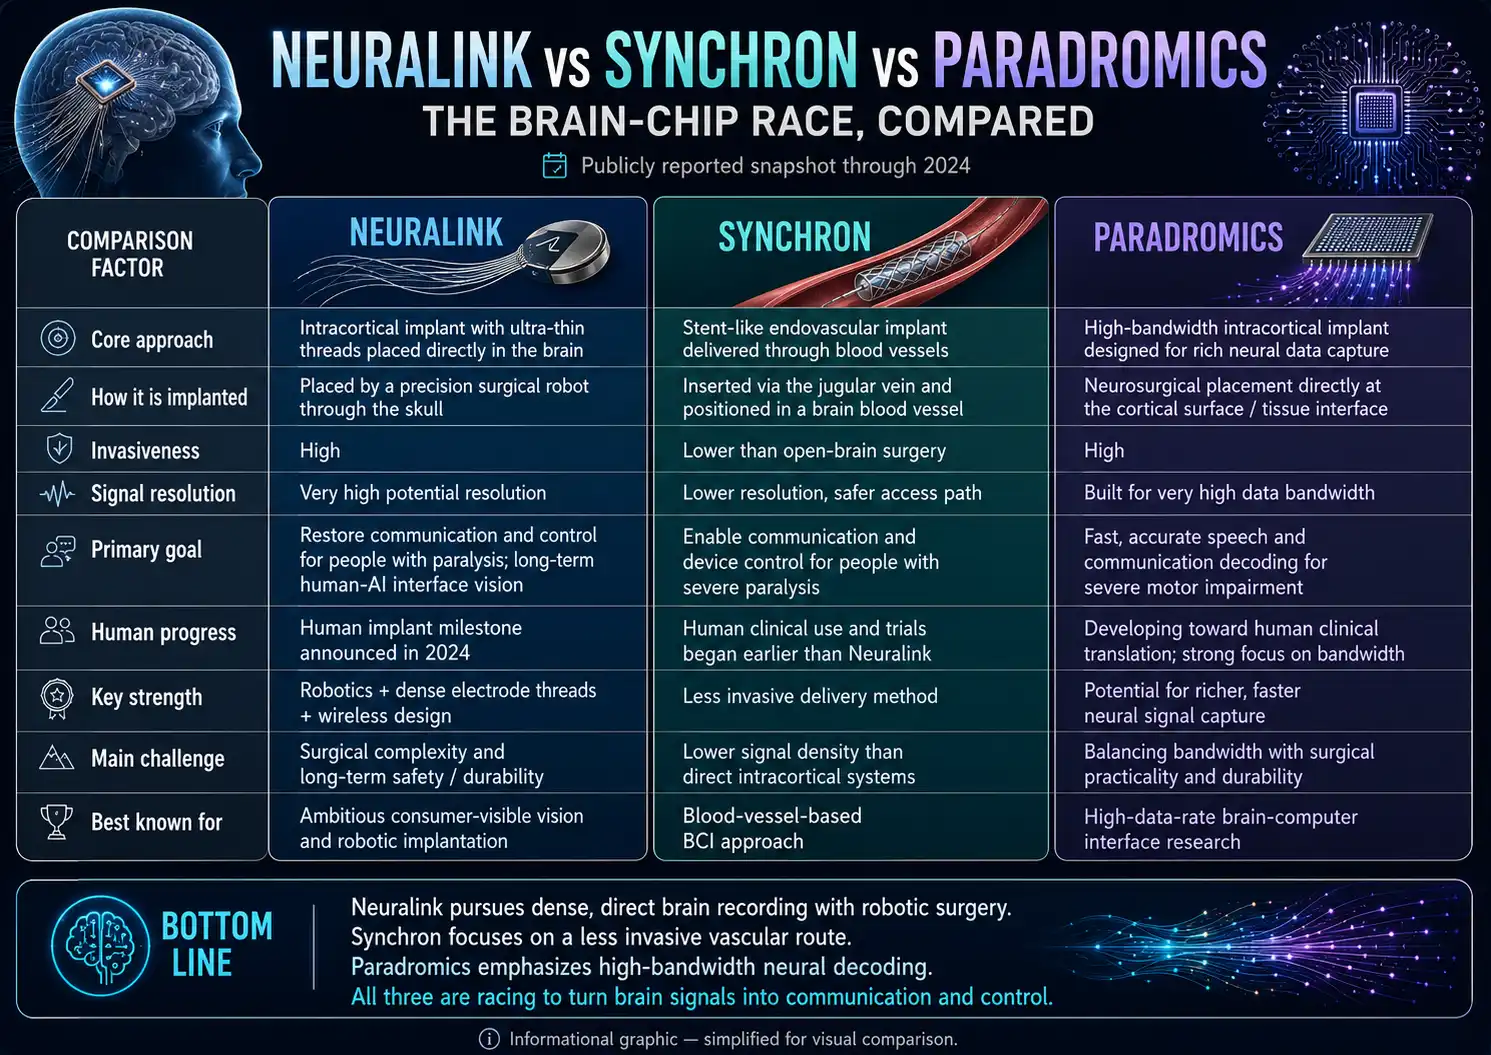
- Invasive: hair-thin electrodes in the cortex itself, close enough to hear individual neurons. The clearest signal, the biggest surgery.
The closer the sensor sits to the source, the less guessing the rest of the system has to do.
Step two: turn noise into features
Raw brain signal is a mess: your own heartbeat, eye blinks, and electrical hum from the room all bleed in. Software filters that out, then pulls out the features that actually carry information: the rhythm of certain brain waves, the timing of spikes, which patch of cortex lit up. This is unglamorous signal processing, and it’s most of the battle.
Step three: the machine-learning guess
Here’s the part people imagine is magic. A model is trained while you repeatedly imagine the same thing, say, moving your right hand. It learns, “when I see this pattern, the person means right hand.” After enough examples, it can see a fresh pattern and predict your intent. It isn’t decoding language; it’s recognizing a signature it has been shown before. That’s why BCIs need calibration, and why they work best on the specific actions they trained on.
What this lets people do
The results are moving. People who are paralyzed have moved robotic arms, controlled cursors, and, with the latest speech BCIs, produced words by having the system decode the neural patterns of attempted speech. Those speech systems get closer to “reading thoughts” than anything before, but notice the mechanism: the person is actively trying to speak, and the model has been trained on their attempts. It’s reading effort, not eavesdropping on idle thoughts.
What kind of model does the guessing
The machine-learning step has a long lineage, and early systems were not deep learning. A widely used approach treats decoding like tracking a moving target: a Kalman filter estimates where a person intends to move a cursor from the firing of many neurons, updating its estimate many times per second. In 2012, Gilja and colleagues showed that a Kalman filter redesigned around how the user corrects the cursor, called ReFIT-KF, halved the time monkeys needed to reach targets and kept performing for years after implantation. Newer speech systems use neural networks that can pull the patterns of attempted speech out of larger recordings, but the principle is the same: learn a mapping from neural activity to intent from examples.
Three results that show the range
The same pipeline of recording, cleaning and decoding gives very different results depending on how close the sensor sits to the neurons. In 1988, Farwell and Donchin described a scalp-EEG speller based on the P300 response, in which the computer detects which flashing letter the user is attending to. In 2012, Hochberg and colleagues showed two people with tetraplegia using a 96-channel array in motor cortex to reach and grasp with a robotic arm. In 2023, Willett and colleagues decoded attempted speech from intracortical arrays at 62 words per minute, with a 9.1% word error rate on a 50-word vocabulary and 23.8% on a 125,000-word vocabulary. Our comparison of EEG, fMRI and ECoG explains why the recording method matters so much.
Why cooperation matters
Privacy research points the same way as the limits above. In a 2023 study, Tang and colleagues built an fMRI decoder that reconstructed the meaning of continuous language, then tested whether it worked without the participant’s cooperation. It did not: cooperation was needed both to train the decoder and to apply it. That supports the point that BCIs decode what a person is deliberately producing. It does not remove the case for rules about neural data as the technology improves.
Why it can’t read your secrets (yet)
A few hard limits keep BCIs honest:
- They decode what they were trained to decode. An unprompted private thought has no label to match against.
- Signal quality drops fast the farther you get from the neurons, so non-invasive devices stay coarse.
- Brains drift day to day, so models need to keep recalibrating.
The privacy questions are real and worth taking seriously. But they’re about future capability and the data these devices collect, not a gadget that prints your inner monologue today.
FAQ
Can a BCI read thoughts I’m not actively having?
No. Current systems decode intent you’re deliberately generating, imagining a movement, attempting to speak. Spontaneous, unprompted thoughts aren’t on the menu.
Do you need brain surgery for a BCI?
Not always. EEG headsets work from outside the skull for simpler tasks. High-bandwidth uses like fluent speech decoding currently rely on implanted electrodes for the resolution they need.
Strip away the mind-reading metaphor and a BCI is a pattern-matcher wired to your nervous system: catch the signal, clean it, and guess your intent from what it has learned. That’s less mystical than telepathy and, honestly, more impressive, because it actually works.
Continue exploring brain-computer interfaces
- Neuralink Blindsight Human Trials: Can It Restore Sight?
- Paradromics Speech-Restoring Brain-Computer Interface, Explained
- China’s Brain-Computer Chip: World-First, But Is It Safe?
- Neuralink and the Next Phase of Brain-Computer Interfaces
- Mind Captioning: How AI Turns fMRI Scans Into Text
- AI Reading Minds: What Neural Tech Can Actually Do
- Will Brain Chips Deepen the Human Class Divide?
Sources
- Gilja et al., “A high-performance neural prosthesis enabled by control algorithm design”, Nature Neuroscience, 2012.
- Farwell and Donchin, “Talking off the top of your head: toward a mental prosthesis utilizing event-related brain potentials”, Electroencephalography and Clinical Neurophysiology, 1988.
- Hochberg et al., “Reach and grasp by people with tetraplegia using a neurally controlled robotic arm”, Nature, 2012.
- Willett et al., “A high-performance speech neuroprosthesis”, Nature, 2023.
- Tang et al., “Semantic reconstruction of continuous language from non-invasive brain recordings”, Nature Neuroscience, 2023.
How we checked this: we compared the figures above with each paper’s published abstract and record.